Team Lead, Mechanical Lead, Member | Nichols High School | Dec 2019 - May 2023
FRC Robotics
FIRST Robotics Competition — Four seasons and my High School Senior Capstone
2023 Competition Robot Autonomous Run
Skills Applied
Robotics
Leadership
Member Development
OnShape
Machining
Proof of Concept Designs
FRC Overview
Project Objective & Key Requirements
FRC drops a new game and a six-week build window every January. Across four seasons on my team’s mechanical sub-team, the objective was always the same: design, build, and iterate a robot capable of scoring reliably under match pressure. Pictured to the right was our 2023 competition robot!

2023 Competition Robot at Regionals Placing Cone

Team Photo
Leadership & Experience
Roles & Contributions to the Team
Over my four years on the team, I developed my technical and leadership skills and went from a team member to the mechanical lead, and then the team captain my senior year. It was an absolute joy to be able to win a competition and leading 50+ students to the World Championships in 2023.
Additionally, after my junior year, our team's mechanical mentor departed. With all the seniors gone, I knew that I would need to prepare myself and further my knowledge of building an FRC robot to prepare the team for next year's competition.
High School Capstone Robot
Design of my Own FRC Robot
Over the summer after our mentor left, I fully designed and built a complete FRC robot for the previous year's game. The goal of this game was to shoot large tennis balls into two different scoring hubs.
My design philosophy was to work ground up. I started with the drivetrain, then planned out the ball path through the robot, and lastly working on system integration between the three subsystems.
My design principles were to design for adjustability, focus on effective solutions to problems without over-engineering, and creating modular subsystems for easy assembly and iteration.

CAD of Capstone Robot

Capstone Robot Fully Assembled at Competition
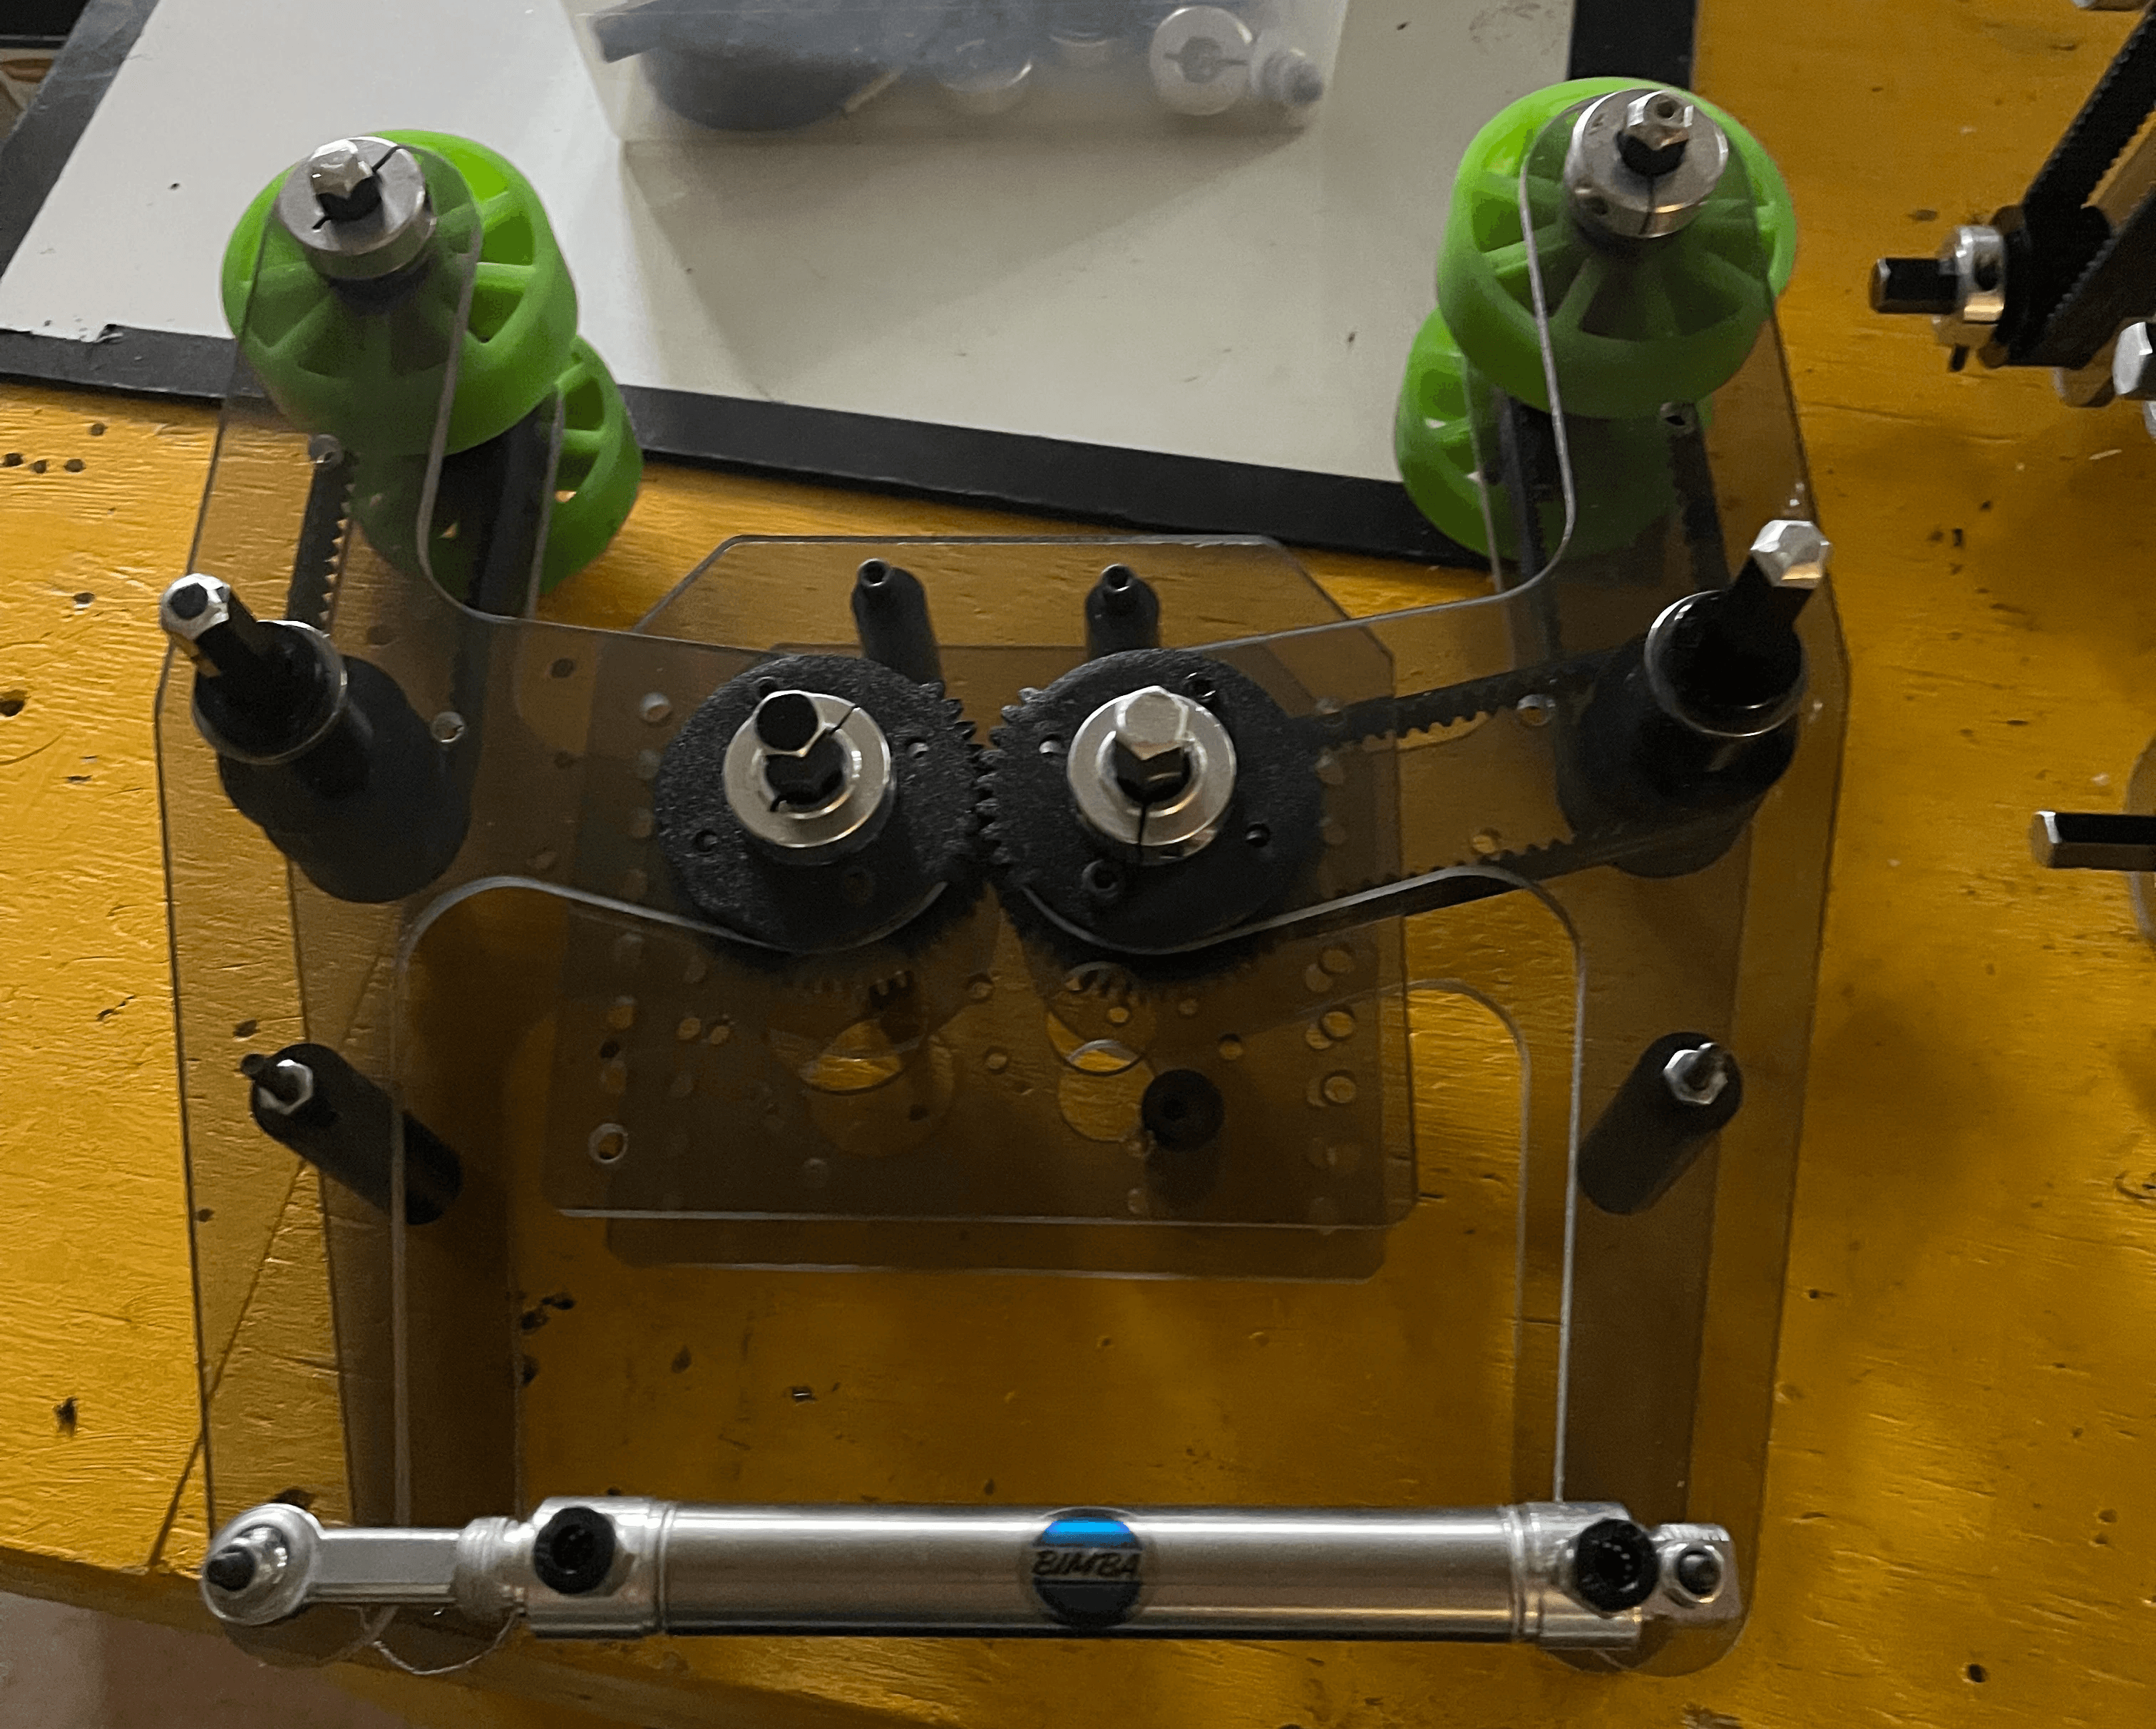
First Tests of 4-Bar Design Assembled

Two-Section Indexer with Balls Indexed

Shooter in Action in First Position
Subsystem Design - Capstone Robot
Three Modular Subsystems
The robot consisted of three main subsystems: intake, indexer, and shooter, all described below:
Pneumatic 4-Bar Intake:
Uneven 4-bar design to allow for small package when retracted into robot
Dual pneumatic piston to deploy and retract
Varying wheel diameters and funnel flanges to guide balls into the indexer
Two-Section Belt Driven Indexer:
Two sections to hold two balls, each with independent motor and belt assemblies
Counter-rotating sides to advance ball upwards
Integrated with the shooter as one polycarbonate assembly with each side being identical
Two-Position Flywheel Shooter:
Dual, counter-rotating wheels to eliminate backspin
Pneumatically controlled hood to change shot trajectory
Modeled 8-foot scoring hub in CAD to determine required shooting angles for successful scoring
Results & Outcomes
Outcomes & Learnings
I am very lucky for my whole experience with High School Robotics. I was lucky enough to bring my robot to a off-season competition to have team members get ready for the season and test out driving it! With the limited testing and programming time, the robot performed very well. Because of this project, I was prepared to be the Team Captain for the 2023 competition season. During the competition season, we decided to go big and try to place cones at the highest level. I think if I were to redesign the arm, I would've chose to reduce its length and go for the lower level so that it wasn't so heavy. This made maneuvering while the arm was extended very difficult.